Control modes & limitations
The Chinese manuals describe the modes below. Mode availability and parameter ranges depend on the controller and SDK version.
| Mode | Purpose | State shown in the source UI |
|---|---|---|
| Joint position following | Move using joint targets | 1 |
| PVT | Execute an uploaded time-based joint trajectory | 2 |
| Joint impedance | Compliant motion in joint space | 3 |
| Cartesian impedance | Compliant motion in a base or TCP frame | 3 |
| Impedance force control | Apply force in a selected direction | See matching guide |
| Drag teaching | Guide the arm and optionally record a trajectory | See matching guide |
PVT requires an explicit trajectory
The manual gives a 2 ms point interval for its PVT implementation. It warns against selecting Run before uploading the intended trajectory: a pre-existing trajectory may already be stored under an identifier. Review positions, timing, velocity, and the physical path before execution.
Speed and acceleration apply only in Position mode
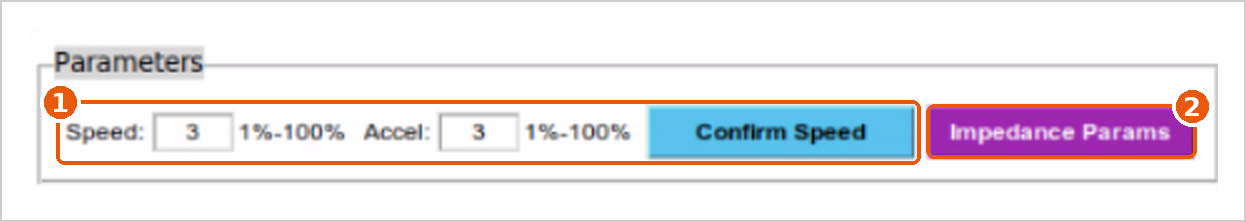
In Marvin Platform's Parameters panel, Speed and Accel set the arm's speed and acceleration as a percentage (1–100%) of its maximum. Click Confirm Speed 1 to apply them. They take effect only in Position mode, which you select in the Status switching drop-down.
In the impedance modes (Joint Impedance, Cartesian Impedance, and Flange Cart.Imp.) and in PD feedforward mode, which runs in Joint Impedance, changing Speed and Accel has no effect. To change how the arm moves in these modes, click Impedance Params 2 and adjust the stiffness (K) and damping (D) values:
- Set joint impedance parameters for Joint Impedance and PD feedforward mode. Enter 7 values for K and 7 for D, one per joint, separated by commas.
- Set cartesian impedance parameters for Cartesian Impedance and Flange Cart.Imp.
Change K and D in small steps, and test each change with the E-stop within reach.
Impedance parameters are version-specific
Cartesian stiffness limits differ between controller and software versions, so there is no single default gain set. Use the values for your arm, tool, and controller.
Advanced control and service functions
PD feedforward mode is set by the robot.ini file; see Set up the configuration files for your arm. MIT control, encoder zeroing, and sensor-offset changes are advanced service functions and aren't covered in these getting-started guides. Contact Gento support before using them. To release the brakes after a collision, follow Move an arm out of a collision.