Troubleshooting & support
Start with the symptom
| Symptom | First checks |
|---|---|
| No live feedback | Power, Ethernet connection, controller IP, subnet, firewall, and matching SDK. See Connect your PC |
| Apex cannot connect | Robot-side power, cabling, router/switch, IP settings, and installed package versions |
| Arm reports an error | Record the exact code and control state before clearing anything. If the arm is stuck in a collision, see Move an arm out of a collision |
| Headset loses power or shuts down | Stop teleoperation immediately; follow the matching recovery guide |
| Tool behaves unexpectedly | Stop and verify tool configuration, wiring, and software compatibility |
Move an arm out of a collision
If a Marvin or Marvin Pro arm stops with an error after hitting something, use Marvin Platform to clear the error and release the brakes, then move the arm away by hand.
With the brakes released, the arm can drop under its own weight. One person operates Marvin Platform; the other holds the arm the whole time. Keep the E-stop within reach, and agree on clear calls ("releasing", "hold") before you start.
The buttons are in the Error Handling section of each arm's panel, numbered below in the order you click them:
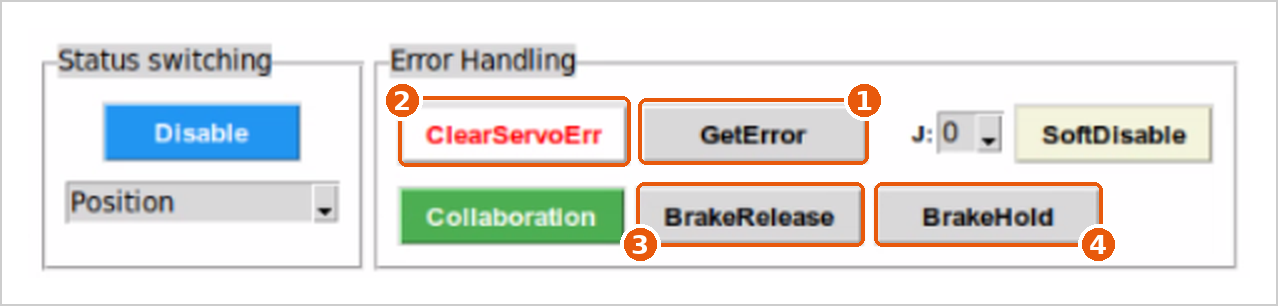
- Connect Marvin Platform to the robot.
- In the panel for the affected arm (LEFT ARM or RIGHT ARM), under Error Handling, click GetError 1 and write down the error code. Then click ClearServoErr 2.
- The second person takes a firm hold of the arm and supports its weight.
- Click BrakeRelease 3, then click OK on the reminder that appears.
- Move the arm slowly by hand out of the collision to a safe position.
- Keep holding the arm and click BrakeHold 4. Let go only once the brakes have locked.
Before you run the robot again, find out what caused the collision and check the arm and tool for damage. If the error comes back, contact Gento support with the code you recorded.
More troubleshooting guides
- Teleoperation troubleshooting and FAQ: quick checks for Marvin Pro, Skye, and Luna, plus cameras, headset network, and version mismatches
- Camera preview fails with
Failed to create CaptureSession: see Cameras - Communication checks you can paste into a terminal: Marvin Pro and Skye/Luna
Collect useful information
Send Gento the robot and arm model, controller/SDK/Apex versions, exact error code, steps leading to the problem, and relevant screenshots or logs. Note whether the issue affects one arm or both and whether it began after an update or tool change.
The troubleshooting resources include the JMDT drive alarm manual and an x86 log retrieval guide. Use the alarm manual that matches the installed drive.
Open troubleshooting resources.
Contact Gento
Email support@gentorobotics.ai.
Repeatedly clearing a fault without identifying its cause is not a recovery procedure. Release the brakes only as described in Move an arm out of a collision. Encoder zeroing and firmware changes require the applicable service instructions.