Apex Teleop: Marvin Pro interface
This page applies to the current Marvin Pro with a Tianzhun controller. The current controller source-review target is gento-apex 1.1.7.1 with Gento SDK 4.7.1; the source still marks this target as unreleased. At customer sites, follow the delivery manifest and use the host application and headset client from the same release.
Interface overview
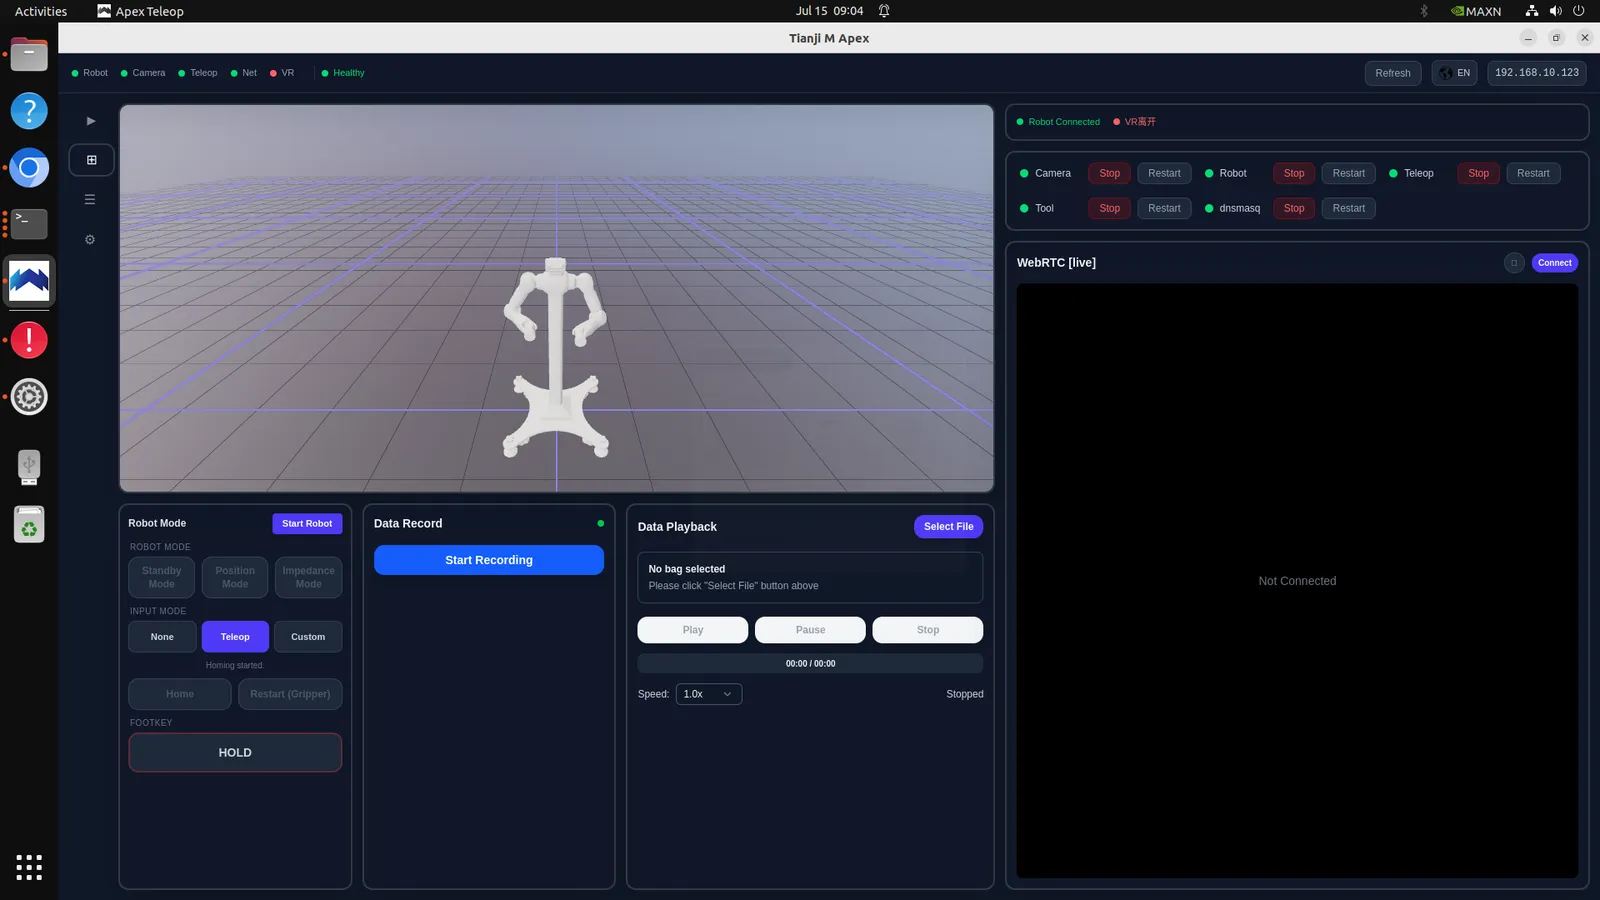
| Area | Purpose |
|---|---|
| Top status bar | Robot, Camera, Teleop, Net, VR, and Healthy states |
| Controller IP | Enter the Tianzhun controller IP and press Enter |
| 3D view | URDF model and live robot pose |
| Module controls | Camera, Robot, Teleop, Tool, and dnsmasq controls |
| Robot Mode | Set Ready, robot mode, input mode, Home, and gripper restart |
| Data Record | Robot and camera data recording |
| Data Playback | Recorded data selection and playback |
| WebRTC | Four-tile camera stream |
| Side navigation | Main, log, and settings pages |
First teleoperation sequence
Follow Marvin Pro: first teleoperation for the sequence from connecting to the controller to teleoperating.
If both arms hang vertically close to the center column, the robot is still in its factory packing pose, and Home can drive a wrist camera into the column. First exit the packing pose.
Module controls
| Module | Required | Description |
|---|---|---|
| Robot | Yes | Connects the robot and publishes robot state |
| Teleop | Yes | Starts the teleoperation chain |
| dnsmasq | Yes | Provides network service for a wired headset |
| Camera | Optional | Starts four-camera streaming and WebRTC |
| Tool | Optional | Controls a configured gripper or end effector |
Green indicates that a module is running. Dependent controls may remain unavailable until Robot is running and the robot is Ready.
Robot Mode
Robot control modes
| Control | Description |
|---|---|
| Start Robot | Sets the robot Ready |
| Standby Mode | Does not execute external motion commands |
| Position Mode | Position control mode |
| Impedance Mode | Compliant mode used for teleoperation |
| Home | Moves to the configured teleoperation initial pose; from the factory packing pose, first enable drag mode, manually move to the standard zero pose, and disable drag mode before clicking Home |
| Restart (Gripper) | Restarts a configured gripper |
Input modes
| Mode | Description |
|---|---|
| None | No external motion input |
| Teleop | Teleop/QP output; used for both headset teleoperation and VLA Cartesian control |
| Custom | Joint targets from a customer application; not for VLA Cartesian control |
See Teleoperation Modes and Input Sources for mode relationships, IK switching order, and full-body/dual-arm/base procedures. Read Customer integration interfaces before using Custom mode.
Camera view
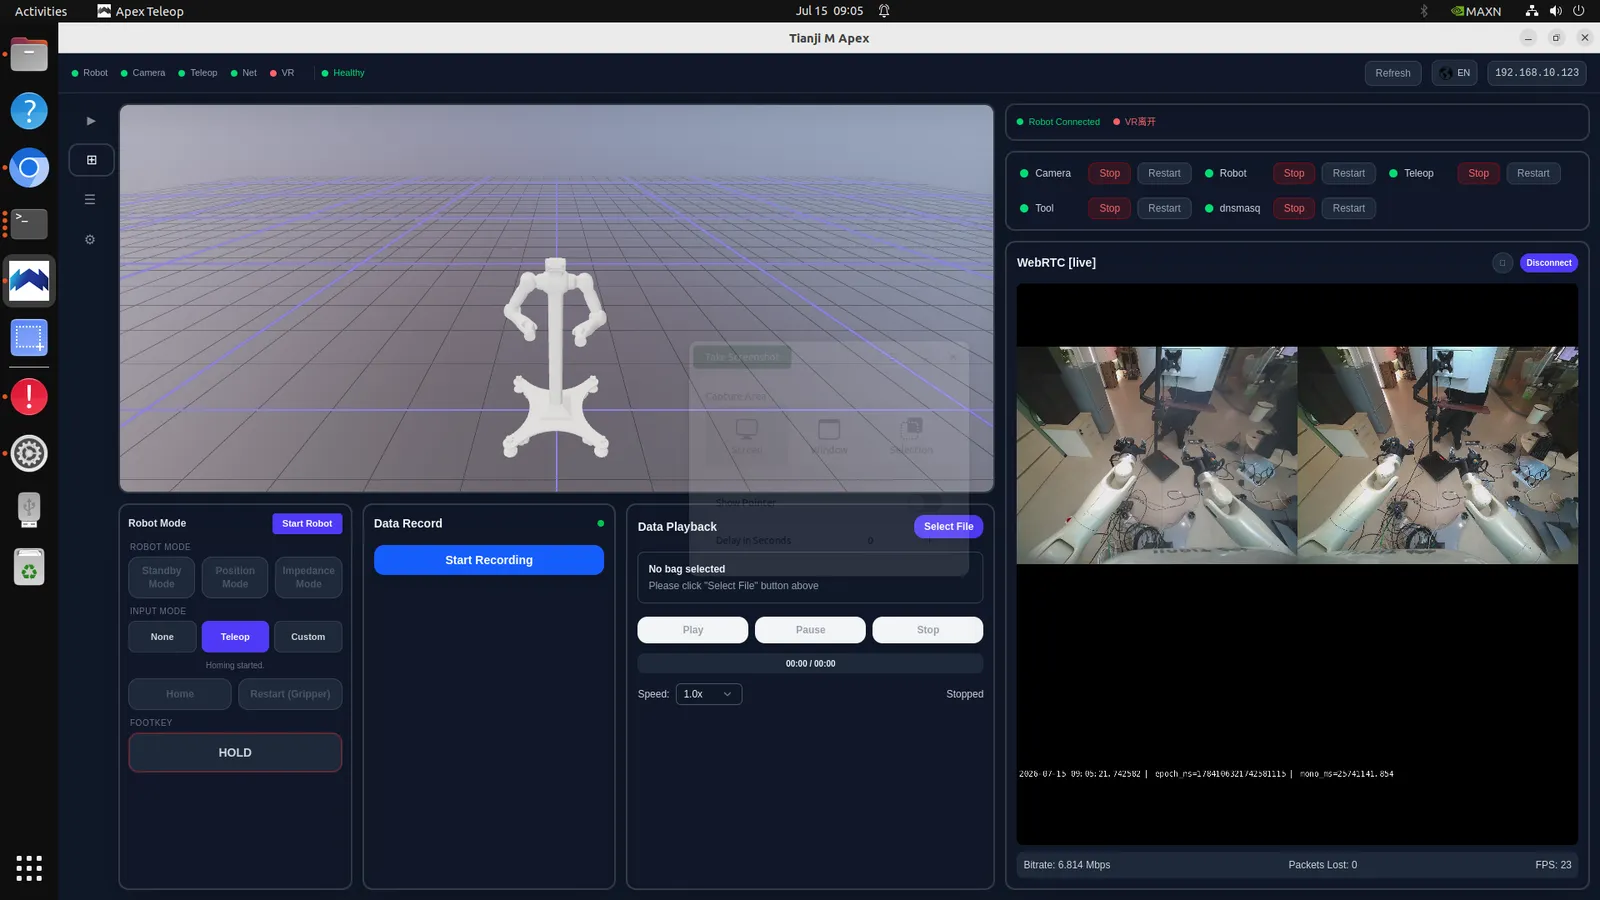
The camera panel always uses a four-tile layout. In the example, camera_sources: [0, 1, none, none] enables two cameras, so the lower two tiles are black by design. This does not indicate a camera fault. Bitrate, packet loss, and FPS are shown at the bottom.
Recording
- Connect the USB drive, set its volume label to
BAG_STORAGE, and confirm that it is mounted at/media/<user>/BAG_STORAGE. - Click Start Recording.
- Keep Robot, Teleop, and any required Camera module running.
- Stop recording and wait for writing to finish before removing the drive.
Recordings are stored by default in:
/media/<user>/BAG_STORAGE/recorded_bags
Each my_bag-* task directory should contain at least data/*.mcap, data/metadata.yaml, and video/cameras.mp4. If files are missing or MCAP cannot be read, first check for an interrupted recording and verify that the USB drive is writable.
To determine whether a topic is permitted for recording, playback, or frontend forwarding, see Topic whitelist configuration and diagnostics.
Playback
- Click Select File and choose a recording.
- Use Play, Pause, and Stop.
- Select the playback rate from Speed.
Before physical playback, clear the workspace, verify the initial pose, and keep the emergency stop within reach.
Logs
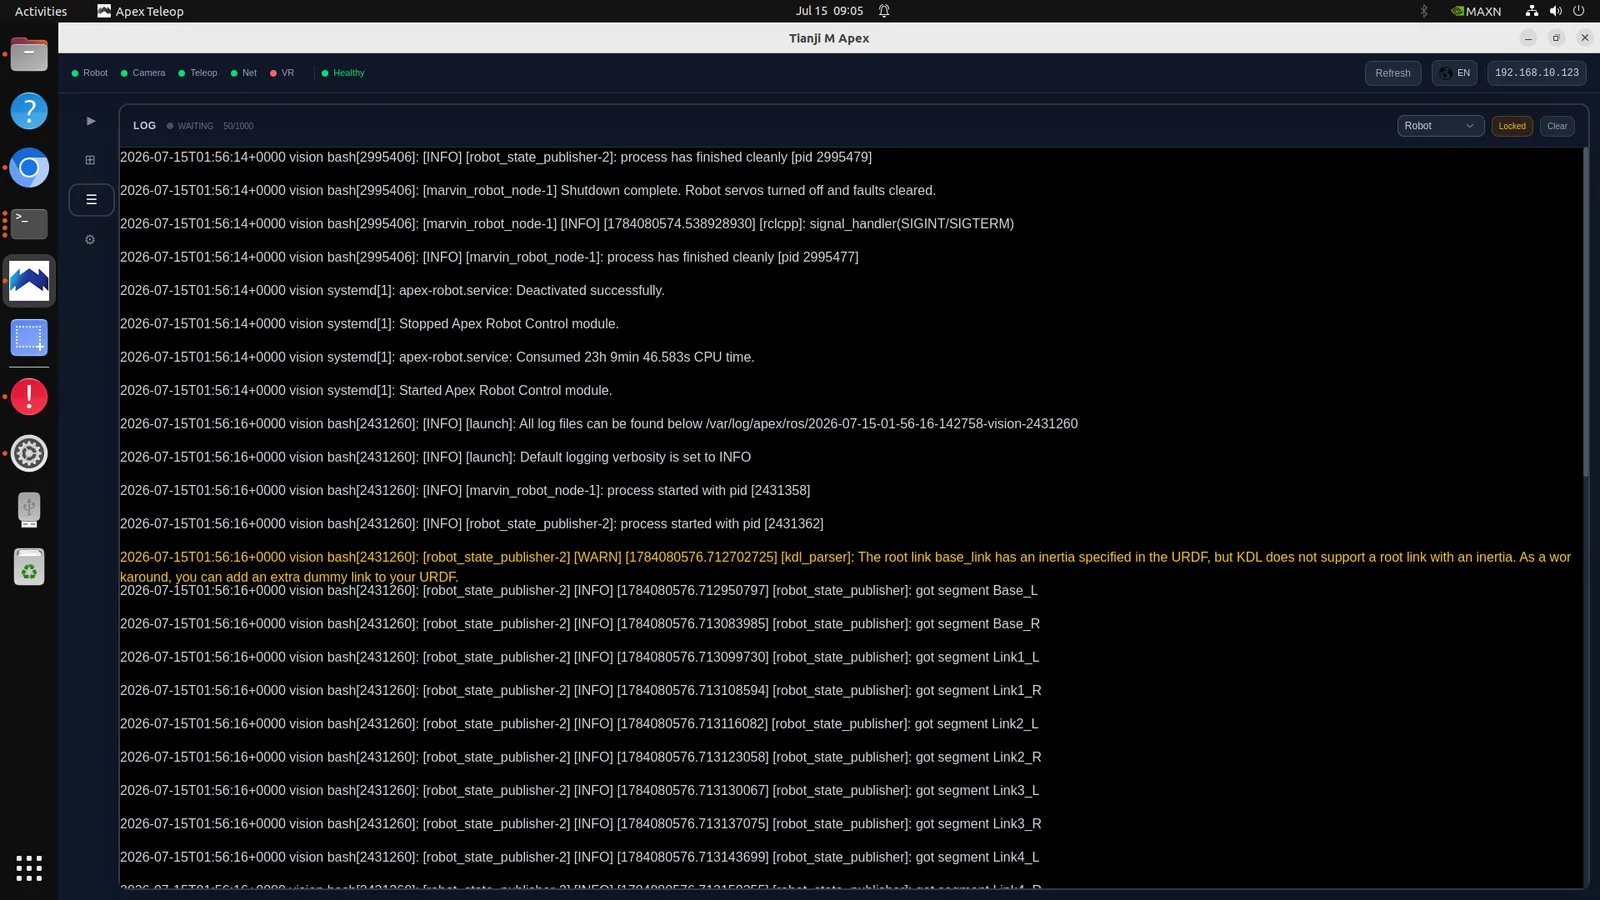
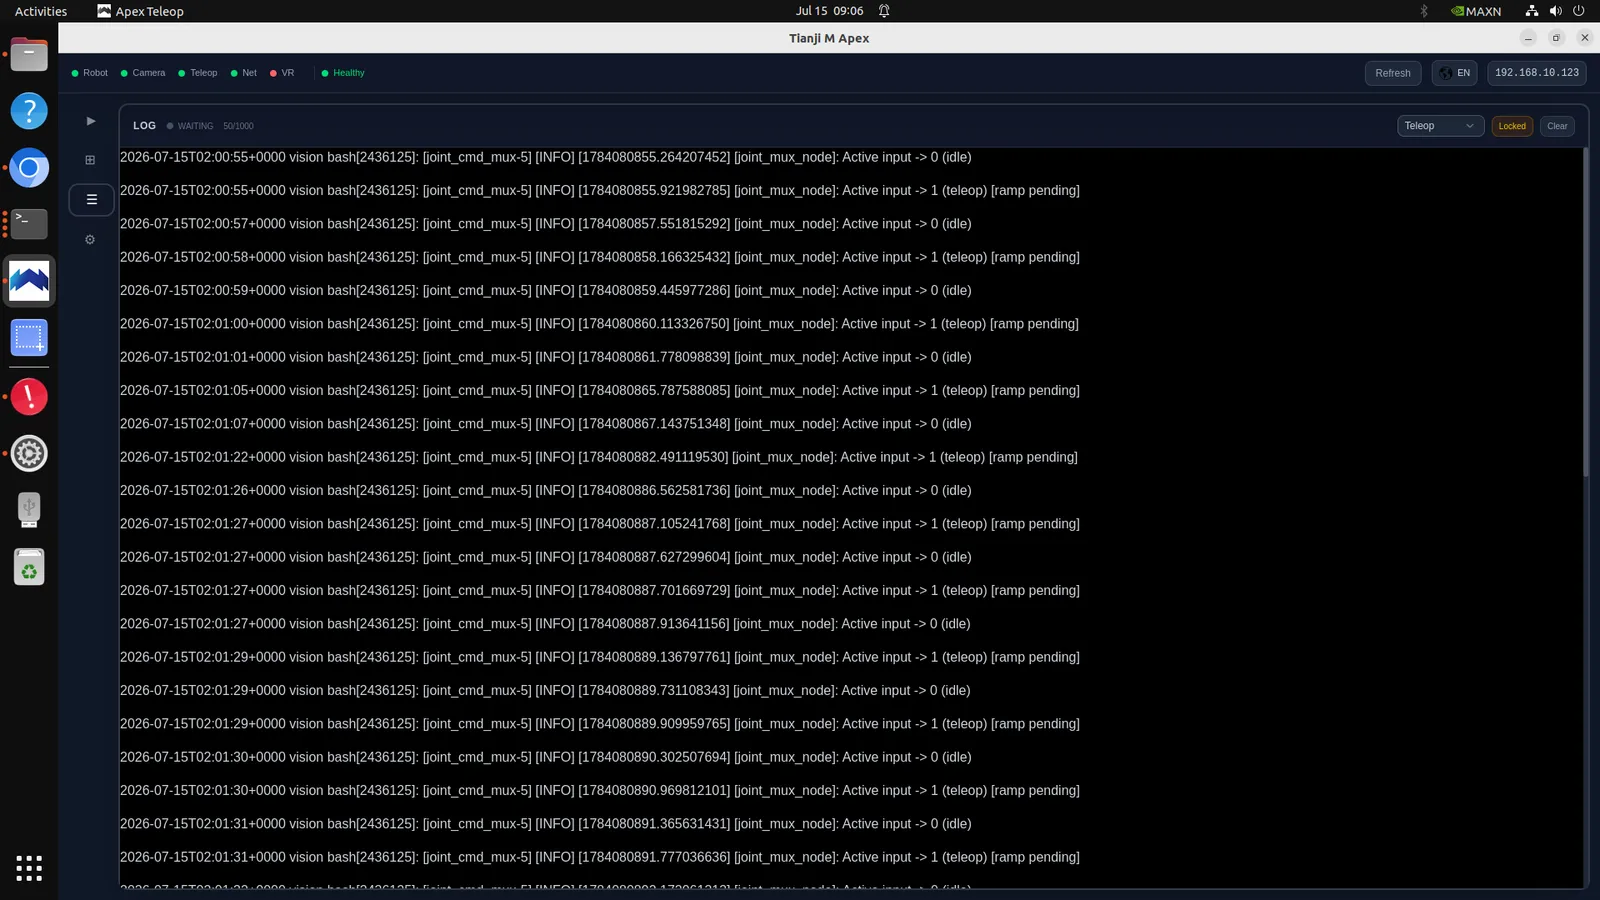
Open the log page from the left navigation and select a module from the upper-right list.
| Control | Description |
|---|---|
| Module list | Switches between Robot, Teleop, and other module logs |
| Locked | Holds the current scroll position |
| Clear | Clears the currently displayed log |
Record the fault time and inspect both Robot and Teleop logs. Do not diagnose a fault from status indicators alone.