SDK quick start
Start by connecting and reading feedback in Marvin Platform. The Pro manual recommends learning the application's operation before writing SDK control code.
Identify your arm model
Before you set up Marvin Platform or the SDK, find out which arm model you have. Build scripts, calculation files, and URDF models are specific to it.
- Find the nameplate on the gray control box: the integrated box on Marvin Pro, or the controller box on Marvin.
- Read the Motion range (最大臂展) field. It shows
Single-armfollowed by a number: the reach of one arm in millimetres. - Use that number to identify the arm model.
Single-arm 696is the standard arm, the M6S-CCS-696 (696 mm reach).Single-arm 809is the M6S-CCS-809 (809 mm reach).
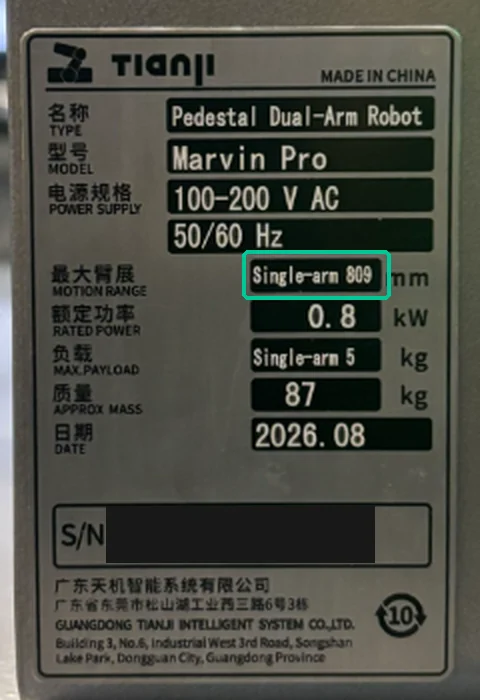
Also check the controller firmware version. You need both to pick the matching build script, and the arm model to pick the URDF on the Resources page.
Get the matching package
The September software guide points to the full master branch of TJ_FX_ROBOT_CONTRL_SDK.
# Retrieve source only. This does not connect to or move a robot.
git clone --branch master https://github.com/cynthia-you/TJ_FX_ROBOT_CONTRL_SDK.git
cd TJ_FX_ROBOT_CONTRL_SDK
Record the checked-out commit and confirm it matches your controller. The SDK's default configuration files are for the standard M6S-CCS-696 arm.
Set up the configuration files for your arm
The SDK comes with configuration files for the standard M6S-CCS-696 arm. For any other arm, or to switch between standard and PD feedforward mode, replace them before you use Marvin Platform or the SDK. More arm models will be added to the download folders.
TJ_FX_ROBOT_CONTRL_SDK/
├── robot.ini                 ← step 1: replace its contents
└── CommonConfig/
    └── config/
        └── ccs_m6_40.MvKDCfg ← step 2: delete it and add your arm's file
-
robot.ini. Open
robot.iniin the SDK's root folder, replace its entire contents with the file for your arm and mode, and save it. Keep the namerobot.ini.Arm Standard mode PD feedforward mode M6S-CCS-696 V4.0 M6S-CCS-696-V4.0_100341-43_DTType0.iniM6S-CCS-696-V4.0_100341-43_PD.iniM6S-CCS-809 V4.0 M6S-CCS-809-V4.0_100341-43_DTType0.iniM6S-CCS-809-V4.0_100341-43_PD.iniPD feedforward is a low-latency tracking mode with joint-impedance compliance, mainly used for teleoperation. Otherwise, use standard mode. These files are for controller firmware 100341–100343 (check yours).
-
MvKDCfg. Open
CommonConfig/config/, deleteccs_m6_40.MvKDCfg, and copy in the file for your arm. Leave only one.MvKDCfgfile in the folder: Marvin Platform can't load the model if there's more than one.Arm File M6S-CCS-696 V4.0 ccs_m6_40.MvKDCfg(already in the SDK)M6S-CCS-696 V3.1 M6S-CCS-696-V3.1.MvKDCfgM6S-CCS-809 V4.0 M6S-CCS-809-V4.0.MvKDCfgIf your own code loads an
.MvKDCfgfile, point it to the same file.
Marvin Platform's Configuration comparison update compares robot.ini with the controller's configuration and can upload it, and motion planning uses the .MvKDCfg model. Another arm's files put the wrong parameters into use. Before you upload anything, save the controller's current configuration with Download robot configuration file.
Follow the package's build instructions
Use the controller-specific script table and the README in the selected revision. The Pro V1.0 manual describes Python 3.10+, Pillow, PyInstaller, and matching compiled SDK libraries, but these requirements must be checked against the package you actually use.
First development milestone
- Verify SDK/controller compatibility (check the firmware version).
- Connect using the unit's assigned IP and configured ports.
- Read both arms' state and error feedback without sending motion commands.
- Disconnect cleanly.
- Review the supplied examples before introducing motion.
The Pro manual explicitly describes its SDK demos as R&D examples, not production code. A hardware-tested first-motion example will be added after the target controller, joint conventions, and initial pose are confirmed.