Connect your PC to the robot
Your PC talks to the robot over a direct, wired Ethernet link. Set this up once before you use Marvin Platform, FxStation, GentoPlatform, or the SDK. It takes about five minutes, and the steps are the same for Marvin, Marvin Pro, Luna, and Skye; only the addresses differ.
Before you start
- A Windows or Ubuntu PC with a free Ethernet port. A USB-to-Ethernet adapter works.
- An Ethernet cable. For Marvin, supply your own.
- Administrator rights on the PC, to change network and firewall settings.
- The robot wired and powered on according to its installation guide.
1. Connect the cable
Plug the cable directly from your PC into the robot's control box.
| Robot | Plug the cable into | Robot network |
|---|---|---|
| Marvin (arms) | x86 controller box, port ETH1 or ETH3. With firmware 1004, use the Ethernet port in After the 1004 firmware update | 192.168.1.x (6.6.7.x with firmware 1004) |
| Marvin Pro | Integrated control box | 6.6.7.x |
| Luna | Integrated control box, panel port RJ45 1 | 6.6.7.x |
| Skye | Integrated control box | 6.6.7.x |
Earlier Marvin Pro systems with an Orin controller use 192.168.10.x: the Orin is 192.168.10.123, the arm controller 192.168.10.190, and the router 192.168.10.1. See Earlier Marvin Pro (Orin).
2. Choose an address for your PC
Give your PC a fixed (static) IPv4 address on the robot's network:
| Setting | Marvin (firmware 1003) | Marvin with firmware 1004, Marvin Pro, Luna, Skye |
|---|---|---|
| IPv4 address | 192.168.1.x | 6.6.7.x |
| Subnet mask | 255.255.255.0 | 255.255.255.0 |
| Gateway and DNS | Leave blank | Leave blank |
| Example | 192.168.1.165 | 6.6.7.50 |
For x, choose any number from 2 to 254 that the robot doesn't already use:
| Last number | Reserved for |
|---|---|
1 | Default gateway |
6 | Mobile base |
100 | AI controller (NVIDIA Jetson Orin or Thor) |
123 | Reserved |
190 | x86 motion controller |
Two devices with the same address conflict, and the connection drops on and off. If several PCs share the robot's network, give each one a different number.
3. Set the address on your PC
- Windows 10/11
- Ubuntu
- Press Win + R, type
ncpa.cpl, and press Enter. - Right-click the Ethernet adapter the robot is plugged into, then select Properties.
- Select Internet Protocol Version 4 (TCP/IPv4), then Properties.
- Choose Use the following IP address and enter the IPv4 address and subnet mask from step 2. Leave the gateway and DNS fields empty.
- Select OK, then Close.
To check, open PowerShell and run ipconfig. The Ethernet adapter should list your new address.
- Open Settings → Network.
- Select the gear icon next to the wired connection.
- On the IPv4 tab, choose Manual.
- Enter the address and netmask from step 2. Leave the gateway and DNS empty.
- Select Apply, then turn the wired connection off and on again.
Or set it from a terminal. Replace the connection name and address with yours; /24 is the same as the mask 255.255.255.0.
nmcli connection show        # find the wired connection's name
sudo nmcli connection modify "Wired connection 1" ipv4.method manual ipv4.addresses 6.6.7.50/24
sudo nmcli connection up "Wired connection 1"
ip -4 addr                   # confirm the new address
Many home and office routers also use 192.168.1.x. If your PC is on a Wi-Fi network like that, it can conflict with the robot's network. Turn Wi-Fi off while you work with a Marvin on firmware 1003.
4. Turn off the firewall
The robot streams data to your PC over UDP, and a firewall blocks that traffic. When that happens, ping still works but the software receives no feedback. Turn the firewall off for the network the robot is on.
- Windows 10/11
- Ubuntu
- Open Windows Security → Firewall & network protection.
- Select the network profile marked (active) for the robot connection. A direct link to the robot is usually a Public network.
- Turn Microsoft Defender Firewall off.
If you also use public Wi-Fi, turn the firewall back on when you finish with the robot.
Ubuntu's firewall (ufw) is off by default, but check it:
sudo ufw status      # "inactive" means there's nothing to do
sudo ufw disable
If your IT policy requires the firewall, allow inbound UDP from the robot's network instead. In PowerShell, run as administrator (for Marvin on firmware 1003, use 192.168.1.0/24):
New-NetFirewallRule -DisplayName "Gento robot" -Direction Inbound `
  -Protocol UDP -RemoteAddress 6.6.7.0/24 -Action Allow
To narrow the rule further, the Marvin Pro and Luna SDKs document UDP ports 50000–50010. Confirm the range for your software version.
5. Test the connection
Ping the robot's controllers from a terminal (PowerShell on Windows):
| Robot | Command | Checks |
|---|---|---|
| Marvin (firmware 1003) | ping 192.168.1.190 | x86 controller |
| Marvin with firmware 1004, Marvin Pro, Luna, Skye | ping 6.6.7.190 | x86 motion controller |
| Robots with onboard AI compute | ping 6.6.7.100 | AI controller (Orin or Thor) |
| Robots with a mobile base, such as Luna | ping 6.6.7.6 | Mobile base |
A reply means the link works:
Reply from 6.6.7.190: bytes=32 time<1ms TTL=64
On Ubuntu, ping keeps running until you press Ctrl + C. Use ping -c 4 6.6.7.190 to send just four packets.
Once the controller replies, open your robot's host software:
- Marvin: Connect the host software
- Marvin Pro: Connect & read robot status
- Luna: GentoPlatform or the SDK
For remote access to the Orin or Thor or checking the controller firmware, see Remote access & firmware. To start the cameras, see Start and view the cameras.
After the 1004 firmware update
Updating a Marvin or Marvin Pro controller to firmware 1004 changes how you connect to it:
- The controller's address becomes
6.6.7.190. On Marvin, the old address192.168.1.190no longer answers. - The controller's Ethernet and arm (EtherCAT) ports move. Arm cables left on the old ports won't link, and a normal network switch won't light the EtherCAT ports.
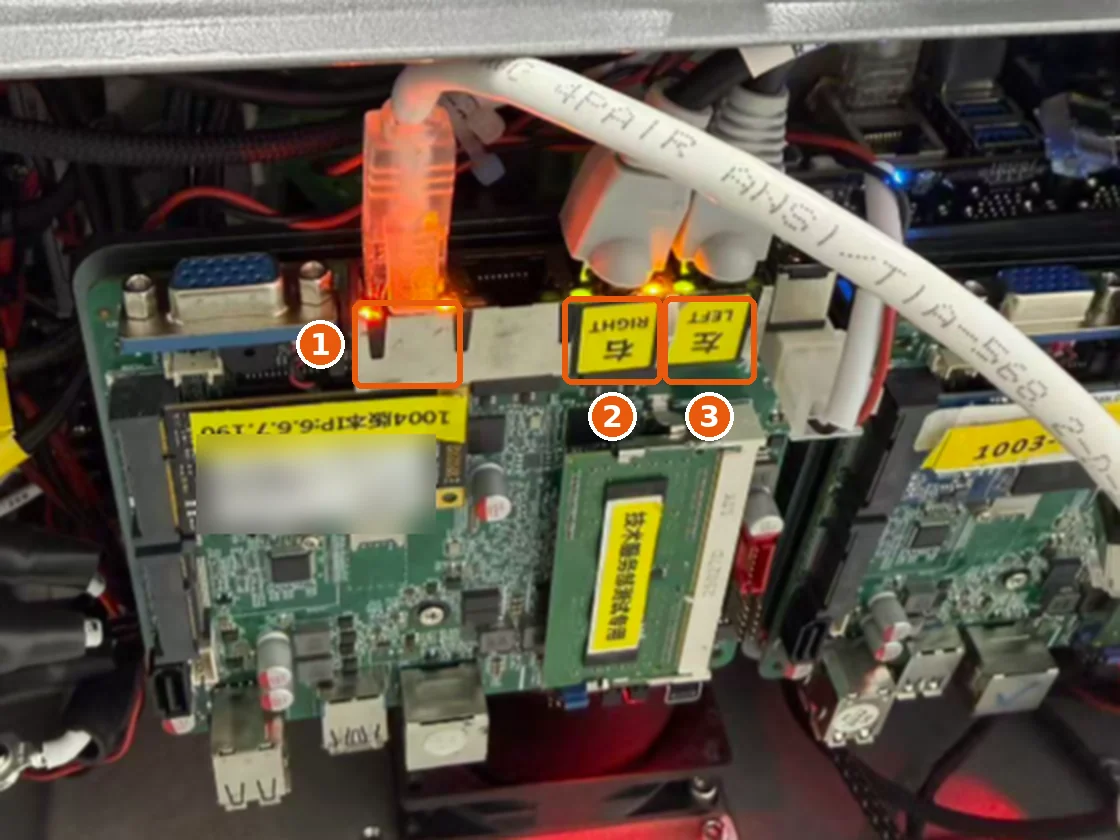
- Power off the robot. On Marvin Pro, the controller is inside the integrated control box: unplug AC power before you open it, and contact Gento support first if you're not sure.
- Reconnect the cables at the controller as shown:
- 1 Ethernet port: the network cable to your PC (on Marvin Pro, the cable that was in the controller's old Ethernet port)
- 2 EtherCAT port labeled RIGHT (右): the right-arm cable
- 3 EtherCAT port labeled LEFT (左): the left-arm cable
- Power on. Set your PC to an address on
6.6.7.xwith subnet mask255.255.255.0, for example6.6.7.100on Marvin. On Marvin Pro,6.6.7.100is the Orin, so use another number such as6.6.7.50. - Test the connection with
ping 6.6.7.190.
The SDK and Marvin Platform must match the controller's major and minor version. The build scripts in these docs are for 1003 controllers ("41" and "43"). After updating to 1004, ask Gento support for the matching software.
Troubleshooting
| Symptom | What to check |
|---|---|
Request timed out or Destination host unreachable | The cable is seated at both ends and in the right port. The robot is powered on and has finished booting. Your PC's address is on the right network (ipconfig or ip -4 addr). |
General failure (Windows) or Network is unreachable (Ubuntu) | The address is set on a different adapter. Repeat step 3 on the adapter the robot is plugged into. |
| Ping works, but the software shows no data | The firewall is still on for the active network profile (step 4), or the software has the wrong controller address. |
| The connection drops on and off | Another device uses the same address. Choose a different last number. |
| Marvin doesn't reply while Wi-Fi is on | Your Wi-Fi network also uses 192.168.1.x. Turn Wi-Fi off. |
| Marvin or Marvin Pro stops replying after a firmware update | After the 1004 update the controller is at 6.6.7.190 and its ports move. See After the 1004 firmware update. |
| Nothing connects while a VPN is on | Disconnect the VPN. Some VPNs send all traffic through the tunnel. |
Still stuck? Email support@gentorobotics.ai with your robot model, your PC's operating system, and the output of ipconfig (Windows) or ip -4 addr (Ubuntu).