Skye overview
Gento Skye is a wheeled lifting humanoid robot. Two force-controlled Marvin arms, a 2-DoF waist, and a head sit on a lifting column, on an omnidirectional chassis with four-wheel drive and four steering wheels. It is a development platform for embodied AI, reinforcement learning, and real-world validation, with whole-body force control as standard and open control access. Motion control and planning (the "cerebellum") come ready, so you can focus on models and algorithms.
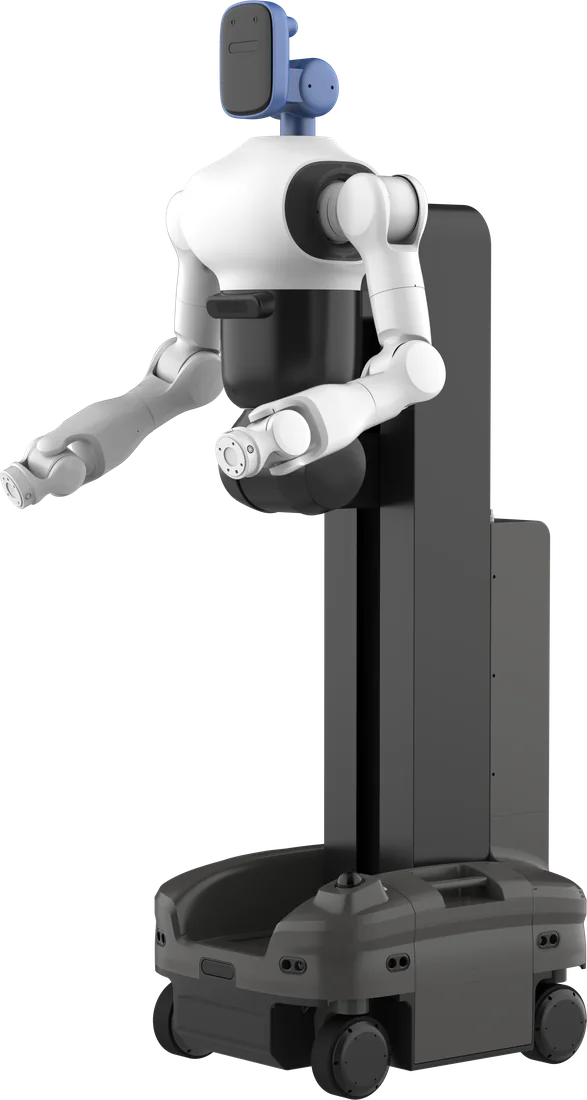
The lifting column moves the upper body through a 785–1685 mm lifting range, so Skye can work from floor level up to about 2 m.
Degrees of freedom
| Section | DoF |
|---|---|
| Head | 2 (pan and tilt) |
| Arms | 7 × 2 |
| Waist | 2 |
| Lifting column | 1 |
| Chassis | 4 |
| Total | 23 (excluding end effectors) |
Main components
| Component | Role |
|---|---|
| NVIDIA Jetson AGX Orin 64GB (standard) or Jetson Thor T5000 (optional) | AI computing (the "brain"): perception and model inference; runs the teleoperation back end |
| x86 motion controller | Motion control (the "cerebellum") for the arms, waist, lifting column, and head |
| Marvin M6S CCS-696 arms | 7-DoF force-controlled arms, 6 kg rated payload each. Other Marvin arms are available as options |
| Head | RealSense D435 RGB-D camera and two SHW5G cameras, stereo speakers, 4-mic array, and RGB light strip |
| Wrist cameras | SHW5G monocular (standard) or RealSense D405GA depth (optional) |
| Linghou TX-S2 chassis | Omnidirectional drive and 3D SLAM navigation, with diagonally mounted 3D LiDARs and ultrasonic sensors |
| LiFePO4 battery, DC48V 34.4Ah | Robot power; manual charging, automatic charging, or quick battery swap |
Arm options
| Arm | Rated payload per arm | Fitment |
|---|---|---|
| Marvin M6S CCS-696 | 6 kg | Standard |
| Marvin M6S CCS-809 | 5 kg | Optional |
| Marvin M3S Long CCS-920 | 3 kg | Optional |
| Marvin M12 CCS-805 | 12 kg | Optional |
| Marvin M20S CCS-1050 | 20 kg | Optional |
The arm values in these pages are for the standard M6S CCS-696.
Suggested reading order
On first use, read in this order:
- Specifications: hardware capabilities and limits
- Unboxing & first use: site preparation, unboxing, and checks
- Interfaces & power: arm end interface, network, ROS 2, and power
- Software, SDK & teleoperation: GentoPlatform, the Gento SDK, and VR teleoperation
- Maintenance & safety: routine checks and safety rules
Skye is heavy, high-power moving equipment; improper operation may cause injury or damage. Read Maintenance & safety before you operate it.
The user manual, URDF model, and product sheet are on Manuals & resources, under the Skye tab. For help, contact support@gentorobotics.ai.