Interfaces & network
Rear control panel
The rear panel brings together power input, control communication, data transfer, and safety interlock interfaces.
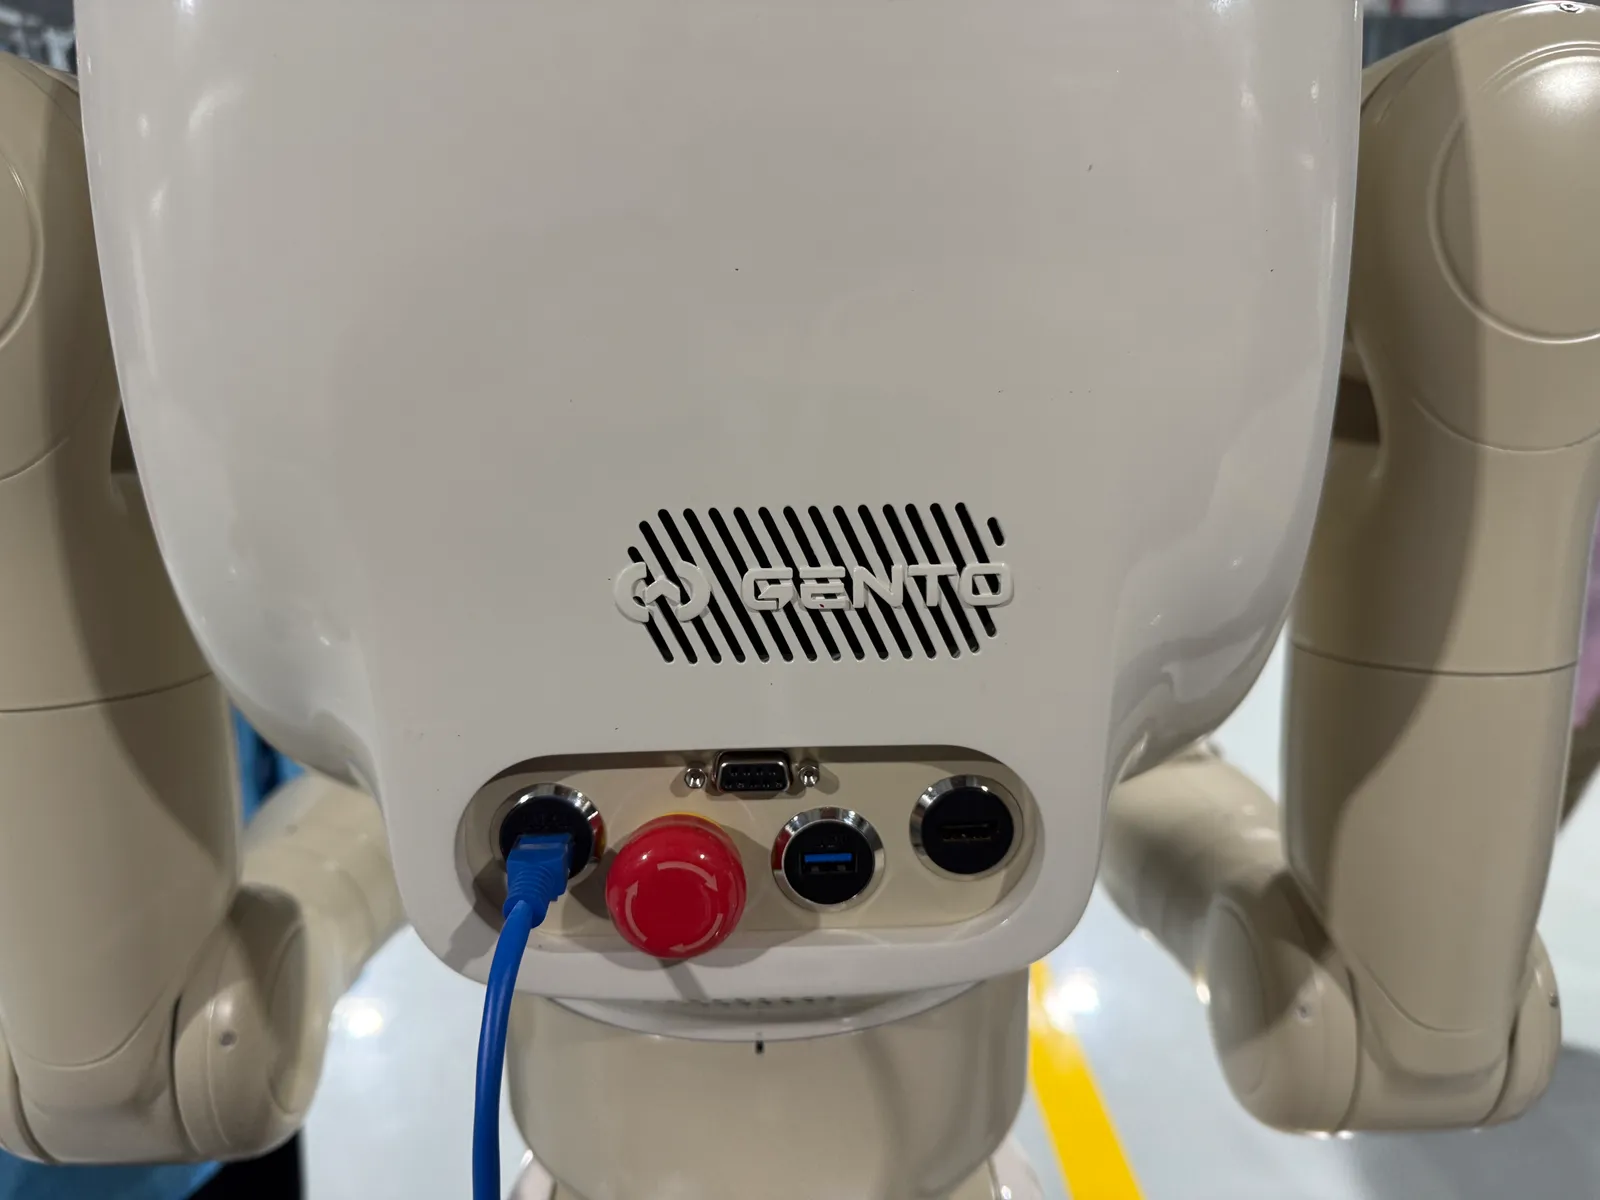
| Interface | Function |
|---|---|
| E-stop button | Self-locking mushroom-head switch that cuts power to critical motion in an emergency (hardware interlock). Press to trigger; turn clockwise to reset |
| Panel Ethernet | RJ45 × 3 for internal controller switching, external host communication, or LAN data. Default subnets: RJ45 1 6.6.7.XX, RJ45 2 6.6.8.XX, RJ45 3 6.6.9.XX |
| USB 3.0 | Type-A × 4 for storage, peripherals, or firmware updates; up to 5 Gbps |
| External interface | Multi-pin industrial signal connector for an external E-stop |
| DM-485 | DB-9 RS-485 port to the joint servo drives (debugging) |
| Panel power | Multi-pin industrial power connector supplying the robot |
Panel power output pins
| Pins | Definition | Power | Notes |
|---|---|---|---|
| 1 / 7 | 48V / 0V | 200 W | Battery supply, 48–60 V |
| 2 / 8 | 24V / 0V | 150 W | 24 V ±5% |
| 3 / 9 | 24V / 0V | 150 W | 24 V ±5% |
| 4 / 10 | 12V / 0V | 150 W | 12 V ±5% |
| 5 / 11 | 12V / 0V | 150 W | 12 V ±5% |
| 6 / 12 | 5V / 0V | 30 W | 5 V ±5% |
External E-stop
As shipped, pins 1 and 4 are shorted, and pins 3 and 6 are shorted. To add an external E-stop, connect 1–4 and 3–6 to the normally closed contacts of the external E-stop box.
DM-485 debug pins
| Pins | Definition | Use |
|---|---|---|
| 1 / 2 | 485A / 485B | Left-arm driver debugging |
| 7 / 9 | 485A / 485B | Right-arm driver debugging |
| 8 / 5 | 485A / 485B | Head and waist debugging |
Arm end 8-pin interface
| Pins | Function |
|---|---|
| 1 / 2 | DC24V power output, 3 A rated |
| 3 / 4 | RS-485 channel 1 |
| 5 / 6 | RS-485 channel 2 |
| 7 / 8 | CAN, CAN FD by default |
Ethernet architecture
The AGV chassis controller, LiDARs, Tianji motion control platform, and external debug ports are linked over Gigabit Ethernet.
| Device | Role |
|---|---|
| NVIDIA Orin (standard) | Central computer: AI algorithms, sensor fusion, device management, network scheduling |
| Tianji Motion Control Computing Platform | Torso and arm motion control, peripheral management; EtherCAT master |
| RJ45 panel debug port | Ethernet debugging and maintenance |
| RDK S100 | AGV chassis controller |
| AGV built-in switch | Gigabit Ethernet inside the chassis |
| Front / rear LiDAR | Perception, mapping, localization, navigation, and obstacle avoidance |
With the optional NVIDIA Thor, Thor becomes the robot's computing center, supports large-model inference (VLA) and multimodal perception, and a chest switch is added for the upper-body network.
EtherCAT architecture
The Tianji motion control platform is the EtherCAT master for every joint driver:
| Slave | Description |
|---|---|
| M6 Left × 8 | 7 left-arm joint drivers; the 8th is the end IO board (× 7 with a dexterous hand) |
| M6 Right × 8 | 7 right-arm joint drivers; the 8th is the end IO board (× 7 with a dexterous hand) |
| Head Pitch | Head pitch |
| Head Rotation | Head rotation |
| Waist Joint 1–6 | Coordinated control of the 6 waist and leg joints |
IP addresses
Connect a cable to panel port RJ45 1 to reach:
| Device | IP address | Role |
|---|---|---|
| Chassis (RDK S100) | 6.6.7.6 | Chassis motion control, status, and system management |
| Domain controller (Orin / Thor) | 6.6.7.100 | AI algorithms, sensor fusion, device management, network scheduling |
| Motion controller | 6.6.7.190 | Torso and arm motion control; EtherCAT master |
Set the debug computer to the 6.6.7.x subnet (for example 6.6.7.50) with netmask 255.255.255.0. For step-by-step setup, see Connect your PC.
The domain controller supports remote desktop login. Login credentials are supplied with the robot; do not record them in shared documents. To use remote desktop without a monitor, see Connect to the Orin or Thor.
Next: GentoPlatform.
Teleoperation network
For Apex teleoperation, the robot's onboard controller (Tianzhun 003 or Lingjing Thor) is at 6.6.7.100 by default. Connect the robot's rear Ethernet port, the host PC, and the headset (through its Type-C Ethernet adapter) to the same router or switch, on the same subnet, with no two devices sharing an address.
Use port 1 with a Tianzhun controller and port 2 with a Lingjing Thor controller. Don't swap them.
For the wiring steps and checks, see Skye and Luna: first teleoperation.